Fixed Scripts vs Adaptive Loops: A Comparative Take on the AMR Controller That Keeps Teams Flowing
A Morning on the Warehouse Floor
It’s 7 a.m., dock doors open, and pallets start streaming in like the tide at Weston. The amr controller wakes, pings the network, and hands out routes while pickers crack on with their lists. Yet before tea break, a choke point appears near aisle three; operators reckon they lose a good chunk of a shift to small stops and re-routes (not a proper job). In many sites I visit, a fifth of mission time slips to idle wheels and muddled handoffs. Why, with clever maps and tidy dashboards, does this still happen—and what’s the simple fix that doesn’t add more screens?
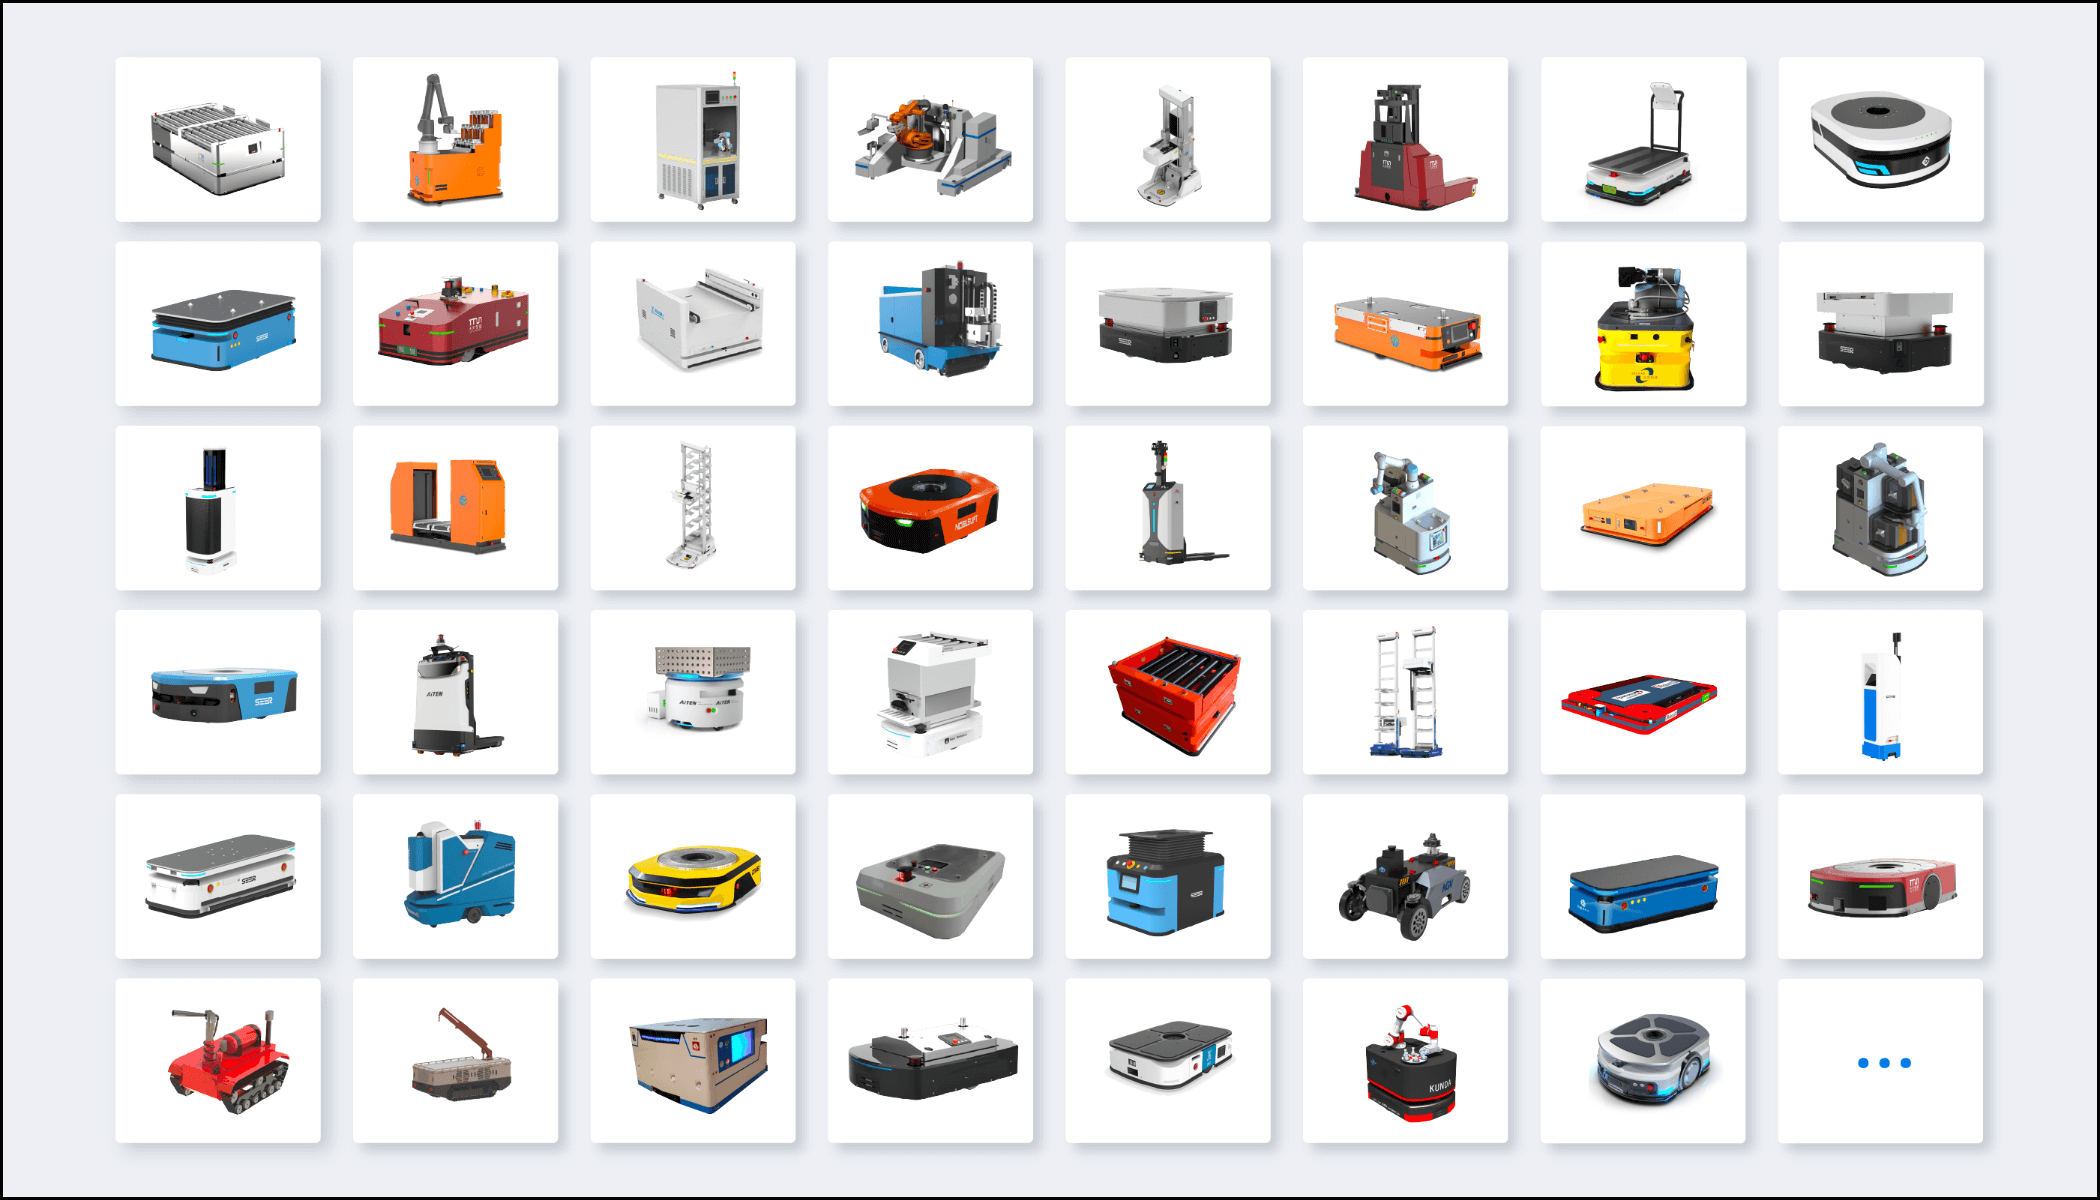
We’ll unravel the gap between smooth demos and busy floors. Then we’ll compare two control styles and show where the gains hide. On we go.
The Hidden Friction in Your Robot Control System
Why does this keep biting us?
At heart, a robot control system runs a loop: sense, plan, act. When that loop drifts, people feel it. Look, it’s simpler than you think. The biggest pain isn’t the map; it’s the handoffs between subsystems. SLAM drift meets tight aisle geometry, and the planner gets twitchy. Sensor fusion waits on late packets because a busy CAN bus adds jitter. Edge computing nodes process vision, but their clocks aren’t synced, so confidence scores wobble. A tiny voltage dip at the power converters pushes motor drivers into a protective shrug. None of these faults are dramatic alone, but together they add up.
Users don’t say “my QoS profile is off.” They say “the bot hesitated, then blocked the lane.” That’s a symptom of timing debt. Configuration lives in four places; one firmware is two versions ahead; recovery policies are too cautious. The amr controller looks fine on a bench. Under load, with mixed payloads and shift changes, the gaps show. And when an operator overrides a route, the control loop restarts cold—funny how that works, right? The cure is not more GUI toggles. It’s tighter contracts between modules, clear failover paths, and feedback that teaches the loop what worked last time.
Comparative Insight: From Fixed Loops to Adaptive Control
What’s Next
Old-school loops are script-first: follow route, replan on fault, repeat. Adaptive stacks treat the robot control system as an event-driven engine. They track intent, not just waypoints. When a pallet skews into the lane, a policy layer weighs options against live constraints and picks the lowest-cost move. Model predictive control nudges speed and heading while watching traction and payload sway. Microservices on edge nodes share state with bounded latency—plan-to-act stays tight even when traffic spikes. The gist: less guessing, more measured change, fewer full resets.
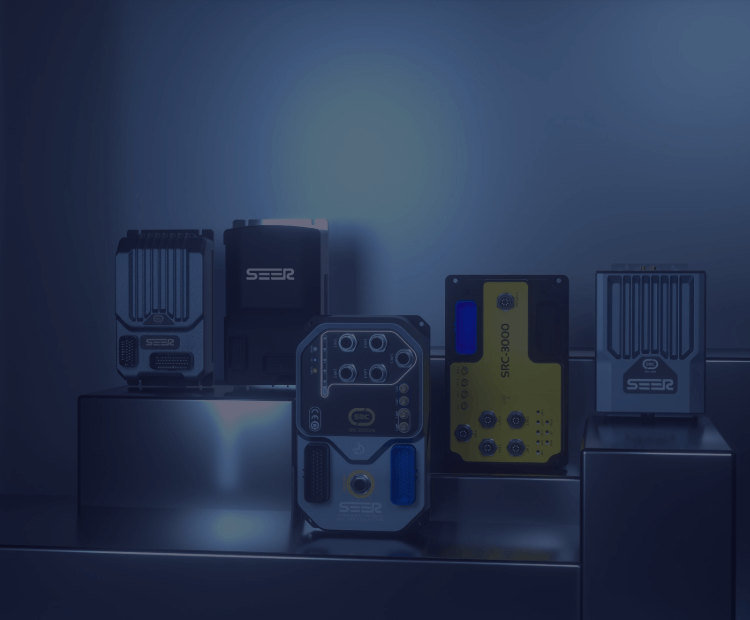
Seen side by side, the difference is plain. Fixed loops hide problems until they pile up; adaptive loops expose them as signals and fold them back into planning. We learned that tiny timing debts, not giant “failed maps,” cause most stalls. We also saw that crisp contracts beat heroics from operators. So, how do you choose a path that scales without fuss? Use three checks: 1) latency discipline—measure p50/p99 plan-to-exec, not just averages; 2) recovery sharpness—seconds from obstacle spotted to stable motion restored; 3) resource headroom—CPU and battery cost per mission under mixed loads. Keep these steady and the floor hums. For further reading on frameworks and controllers built with these ideas in mind, see SEER Robotics.